Niryo Ned2
Niryo · Price on request · Get a current price · Simulate it first
Overview
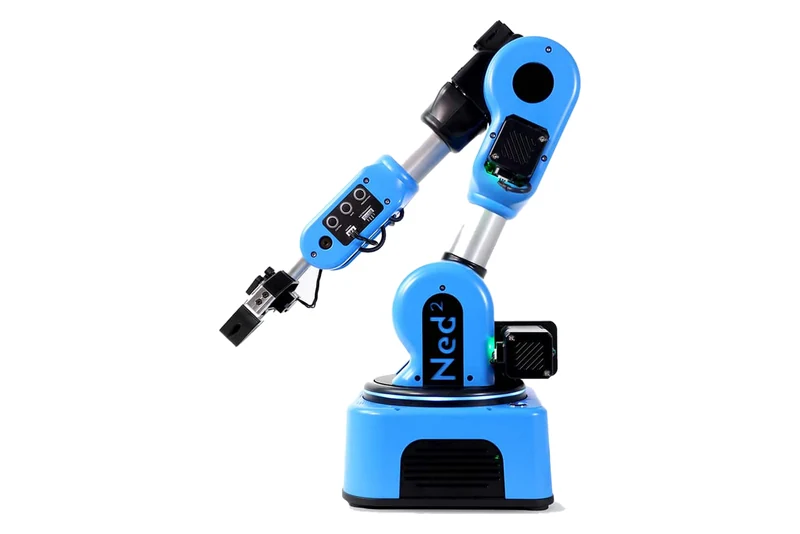
6-axis desktop robotic arm from Niryo for teaching, research and light prototyping. Carries 300 g, weighs 7 kg and has a stated repeatability of +-0.5 mm. Programmed from NiryoStudio (Blockly and Python), with ROS, ROS 2, MATLAB, RoboDK, OpenCV and TensorFlow integrations, plus Wi-Fi, Ethernet, USB and digital/analog I/O for conveyors, IR sensors and a vacuum pump.
Will the Niryo Ned2 do your task? Simulate it before you buy.
Four cobots on the same palletizing task, simulated before purchase.
We build your station in a simulator with the Niryo Ned2 and one or two alternatives, and send you video plus cycle time, parts per shift, reach and payload check, and a payback estimate. Scoping is free, and every project is quoted individually.
Software & 3D models
- URDF: yes
- MuJoCo: not found
- Isaac Sim (USD): not found
- Gazebo: yes
- CAD (STEP): yes
- SDK: yes
- ROS: yes
- ROS 2: yes
- RoboDK: yes
Checked 2026-10-17. Links are not published; we share them with clients.
Variants & pricing
| Variant | Status | Available | Current price |
|---|---|---|---|
| Ned2 | available | — | Contact |
Get a price for the Niryo Ned2
We work from Hangzhou with Chinese and international robot makers. Tell us what you need and we check the current price, lead time and delivery to your country, and reply by email. Our fee comes from you, never from the seller.
A real person reads this. Reply within 2 business days. How we help buyers of robots from China →
Full price history
| Price | Date | Variant | Source | Note |
|---|---|---|---|---|
| Contact | 2026-10-17 | Ned2 | Niryo | Official page is quote-only ('Add to quote' / 'Request a quote'); cart shows 0 EUR and prices exclude import duties and local taxes. No public price. |
Sensors
- Joint position feedback (not detailed on the official page)
- I/O: 3 NPN DI (+ DI4 on electromagnet connector), 3 NPN DO (+ DO4 PNP), 2 AI (12-bit), 2 AO (12-bit); interfaces for 2 conveyors, 1 IR sensor, 1 vacuum pump
Locomotion
fixed mount
Manipulation
Arms: 6 DOF · Hands: Interchangeable tools from the Niryo ecosystem (gripper, vacuum pump, electromagnet connector)
Use cases
education, STEM teaching, research, light pick-and-place prototyping
Software
OS: NiryoStudio (Blockly and Python) · SDK: ✓ · ROS: ✓ · Open source: ✗ · Languages: Python, Blockly · AI: TensorFlow, OpenCV (integrations listed)
Key facts
- Official Ned2 page (fetched 2026-10-17): 6 axes, payload 300 g (0.66 lb) at a 20 mm TCP, repeatability +-0.5 mm, weight 7 kg, dimensions 181.6 x 187.6 x 436.22 mm (W x D x H, pose not stated), 1 year standard warranty, 'sturdy metal chassis'.
- Reach conflict, not resolved: Niryo's official page (niryo.com, fetched 2026-10-17) states 490 mm (19.29 in; highlight 'Reach 49cm/diam 1 m'), while the ROS robots page for the Ned2 (robots.ros.org/ned2/, fetched 2026-10-17) lists 'Max reach 440 mm'. The manufacturer's own page figure is 490 mm; the catalog has no reach field, so neither value is recorded as a spec.
- No price is recorded: dealer listings of about EUR 3,990 excl. VAT (Unchained Robotics, Generation Robots) appeared in search results, but the dealer pages could not be fetched (404, or a different product), so no price entry is added. Price stays null until a fetched dealer page confirms it.
- Not stated on the official page: IP rating, power supply, controller, certifications, operating temperature, launch year. Left null.
- Connectivity from the official page: Wi-Fi 2.4/5 GHz, Gigabit Ethernet (RJ45), 2x USB 2.0, 2x USB 3.0. RoboDK licence included; NVIDIA compatibility listed.
About Niryo
French maker of 6-axis desktop robotic arms for education, research and light prototyping, programmed from NiryoStudio (Blockly and Python) with ROS and ROS 2 support.
https://niryo.com · Founded: None · HQ: France
Last updated: 2026-10-17 · Full dataset (CSV/JSON, CC BY 4.0)