LimX Dynamics Tron1
LimX Dynamics · Starting from $15,000 · Get a current price
Overview
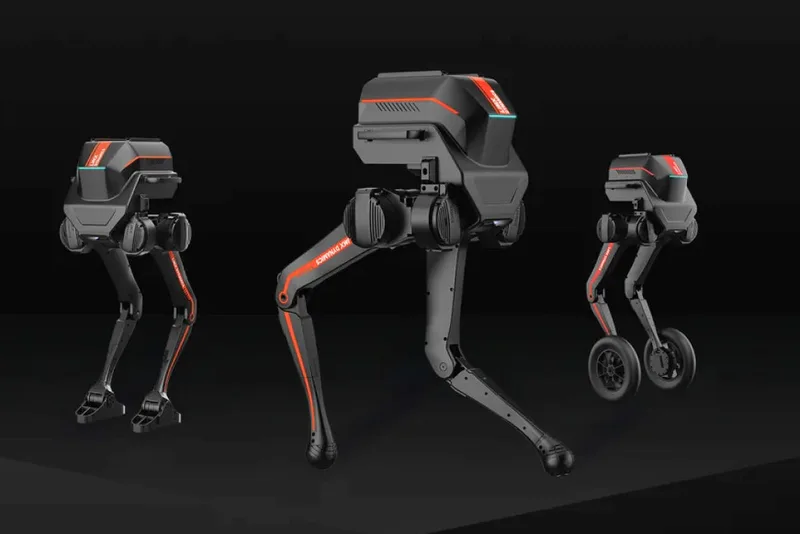
A versatile multi-modal robot designed for embodied AI research. Features a unique 'Three-In-One' locomotion system that can quickly switch between point-foot, bipedal (sole), and wheeled modes. Optimized for reinforcement learning and advanced motion control development.
Software & 3D models
- URDF: yes
- MuJoCo: yes
- Isaac Sim (USD): not found
- Gazebo: yes
- CAD (STEP): not found
- SDK: yes
- ROS: yes
- ROS 2: yes
- RoboDK: not found
Checked 2026-10-17. Links are not published; we share them with clients.
Variants & pricing
| Variant | Status | Available | Current price |
|---|---|---|---|
| Tron1 EDU | available | 2024 | $25,000 |
| Tron1 Standard Edition SDK: No |
available | 2024 | $15,000 |
Get a price for the LimX Dynamics Tron1
We work from Hangzhou with Chinese and international robot makers. Tell us what you need and we check the current price, lead time and delivery to your country, and reply by email. Our fee comes from you, never from the seller.
A real person reads this. Reply within 2 business days. How we help buyers of robots from China →
Not sure it can do the job? We simulate the task before you buy →
Full price history
| Price | Date | Variant | Source | Note |
|---|---|---|---|---|
| $25,000 | 2026-10-16 | Tron1 EDU | LimX Dynamics official store | TRON 1 - Educational Edition, $25,000.00 USD, in stock in the official Shopify store; taxes and shipping at checkout. |
| $15,000 | 2026-10-16 | Tron1 Standard Edition | LimX Dynamics official store | TRON 1 - Standard Edition, $15,000.00 USD, in stock. The store states the Standard Edition does not support secondary development (no SDK access); the EDU edition does. |
| $15,000 | 2025-01-01 | Tron1 EDU | Official store | Base price for education/research version |
Sensors
- IMU
- Optional Sensor Expansion Kit: LiDAR + depth camera
- Optional Voice Interaction Kit: microphone array + NVIDIA NX module
Locomotion
point-foot, bipedal walking, wheeled, stair climbing
Use cases
embodied AI research, reinforcement learning, education, motion control R&D
Software
OS: Linux (Ubuntu) · SDK: ✓ · ROS: ✓ · Open source: ✗ · Languages: Python, C++ · AI: Simulation: NVIDIA Isaac, MuJoCo, Gazebo; Python development, URDF provided
Key facts
- Modular foot-ends switch between point-foot, sole (biped) and wheeled modes; the robot recognises the fitted foot-end automatically.
- Two editions with the same hardware: Standard ($15,000, no secondary development) and EDU ($25,000, open SDK, data recording, joint-level control) — LimX official store, 2026-10-16.
- Official limits: up to 10 kg load, up to 3 m/s in wheeled mode (under 1 m/s on point-foot or sole), 30° slopes and 20 cm obstacles (wheeled), -5 to 40 °C.
- Battery 4.5 Ah at 46.8 V (about 211 Wh, computed from the two published figures), up to about 2 h runtime, quick swap, 1.5 h full charge.
- Joint actuators: 30 N·m rated, 60 N·m peak, 15 rad/s peak speed.
- Category note: TRON 1 is a biped, filed under quadruped only because the catalog has no biped/multi-modal category.
About LimX Dynamics
Focuses on general-purpose legged robots with advanced motion control.
https://www.limxdynamics.com · Founded: 2022 · HQ: Shenzhen, China
Last updated: 2026-10-17 · Full dataset (CSV/JSON, CC BY 4.0)