Used for: Inspection & security Manufacturing
Lenovo Daystar Bot GS3.0
Lenovo Daystar · Price on request · Get a current price
Overview
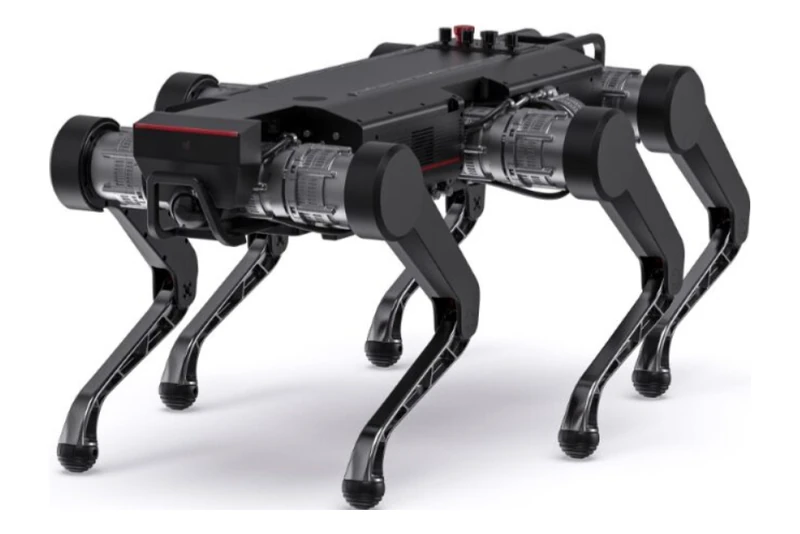
Lenovo's six-legged (hexapod) inspection robot, model GS3.0 in the DaystarBot SDK v2.4 product list: 1160 x 660 x 610 mm standing, 68 kg with battery, a 70 to 100 kg payload range, IP67, 18 joint motors, a 61.2 V / 24 Ah battery with 2.5 to 4 h of runtime and a 1.6 m/s top speed. Compute is an RK3588 plus an NVIDIA Orin NX. It carries LiDAR, an HD camera and an IMU, returns to its charging dock, localises, maps and plans routes on its own, and takes expansion modules such as a dual-light PTZ, robotic arm, gas sensors, and WAPI client. Developed through the Lenovo DaystarBot SDK (C++, ROS 2, Python, C#).
Software & 3D models
- URDF: not found
- MuJoCo: not found
- Isaac Sim (USD): not found
- Gazebo: not found
- CAD (STEP): not found
- SDK: yes
- ROS: not found
- ROS 2: not found
- RoboDK: not found
Checked 2026-10-17. Links are not published; we share them with clients.
Variants & pricing
| Variant | Status | Available | Current price |
|---|---|---|---|
| GS3.0 | available | — | Contact |
Get a price for the Lenovo Daystar Bot GS3.0
We work from Hangzhou with Chinese and international robot makers. Tell us what you need and we check the current price, lead time and delivery to your country, and reply by email. Our fee comes from you, never from the seller.
A real person reads this. Reply within 2 business days. How we help buyers of robots from China →
Not sure it can do the job? We simulate the task before you buy →
Full price history
| Price | Date | Variant | Source | Note |
|---|---|---|---|---|
| Contact | 2026-10-17 | GS3.0 | Lenovo Daystar documentation (official) | No public price on the official SDK/product documentation; no dealer listing found. Industry/enterprise product (1 year warranty per the spec table). |
Sensors
- LiDAR
- HD camera
- IMU
Locomotion
six-legged walking
Manipulation
Arms: None DOF · Hands: None (robotic arm is an optional expansion module)
Use cases
inspection, industrial, public sector, heavy payload carrying
Software
SDK: ✓ · ROS: ✓ · Open source: ✗ · Languages: C++, Python, C#
Key facts
- Official spec table (DaystarBot SDK v2.4 overview, fetched 2026-10-17), GS3.0 column: standing 1160 x 660 x 610 mm, crouching 1280 x 770 x 232 mm, 68 +/-2 kg with battery, aluminium alloy plus high-strength engineering plastic, IP67, physical E-stop, Wi-Fi 5 (5 GHz), expansion interfaces power, LAN Ethernet and USB, 61.2 V nominal and 24 Ah, payload 70 to 100 kg, max speed 1.6 m/s, max drop height 22 cm, max slope 45 degrees, RK3588 + Orin NX, battery life 2.5 to 4 h, max joint torque about 360 N.m (the highest of the 18 motors), 18 joint motors, internal knee wiring, LiDAR, HD camera and IMU, 1 year warranty. Expansion modules listed for GS3.0: dual-light PTZ, robotic arm, WAPI client, gas sensors, etc. (5G CPE client, acoustic/panoramic camera, UWB and RS485 belong to the MX column, not GS3.0).
- height_cm 61 assumes the '1160 x 660 x 610 mm' standing size is length x width x height; the table does not label the axes (an assumption).
- payload_kg is set to 70, the lower bound of the official 70 to 100 kg range (the table does not say static or walking for this model); the full range is in the description. battery_wh 1468.8 is derived from the nominal 61.2 V x 24 Ah (voltage x capacity), not a published Wh figure. battery_hours is null: the official figure is a 2.5 to 4 h range, not a typical value.
- Six legs: the official table gives 18 joint motors and the official render shows six legs (3 motors per leg); the official overview text does not use the word hexapod. The hexapod label comes from press coverage (interestingengineering.com and mezha.media, 2024), not from the fetched official page. Filed under quadruped only because the catalog has no hexapod category.
- Max obstacle height and max range are shown as not applicable (cross) for GS3.0 in the table. Autonomous functions listed as supported: charging-dock return, localisation, navigation planning, obstacle avoidance and mapping; fall recovery is not listed for this model.
- The same table lists three siblings (MC, MX, IS2.0) that are separate models and are not catalogued here. DaystarBot SDK v2.4 supports models MC, MX, ISLite, IS, IS2.0 and GS (languages C++, ROS 2, Python, C#); the quick start recommends Ubuntu 22.04 for the development machine.
- Image: official render of the GS3.0 column from the Lenovo Daystar documentation page (864 px wide source), placed on white.
- year_announced is null: the GS first appeared in 2024 per search-result snippets that were not fetched, and GS3.0 is a later revision with no fetched announcement date. No earlier GS version is in the catalog, so predecessor_id is not set.
About Lenovo Daystar
Lenovo's Daystar legged-robot line for inspection and industrial use, documented with the DaystarBot SDK (models MC, MX, IS2.0, GS).
https://daystar.lenovo.com · Founded: None · HQ: China (Lenovo Group)
Last updated: 2026-10-17 · Full dataset (CSV/JSON, CC BY 4.0)